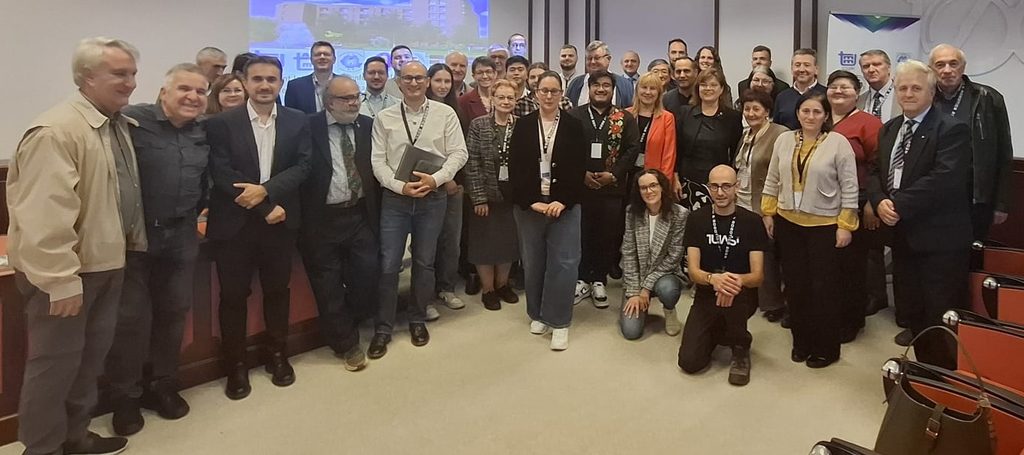
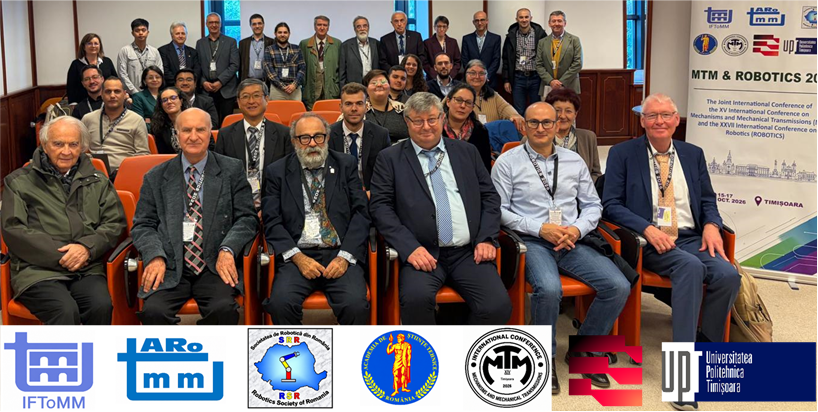
Organized by Department of Mechatronics at University Politehnica Timisoara (UPT) and Technical Sciences Academy of Romania – ASTR with organizing support of:
IFToMM TC for Robotics and Mechatronics
IFToMM TC for Linkages and Mechanical Controls
IFToMM MO Romania – ARoTMM
Robotics Society of Romania– SRR
IFToMM MO Italy – IFToMM Italy
Under the Patronage of IFTOMM International Federation for the Promotion of Mechanism and Machine Science
Number of received papers: 51
Number of accepted papers: 46
Number of presented papers: 44
Number of the registered authors: 55
Number of the participants: 49
Number of countries represented: 14
Japan, Kazakhstan, Russia, Turkey, Siria, Greece, Romania, Serbia, Italy, Czeck Republic, Germany, France, Spain and Mexico
IFToMM for Sustainable Development Goals
The I4SDG congress, now in its fourth edition, IFToMM for Sustainable Development Goals, a novel initiative, within the aims of IFToMM Cross Disciplinary Group 1 (Securing our Future Environment – Air, Water, Energy), entitled IFToMM for Sustainable Development Goals, I4SDG.
Its main aim is to raise awareness on sustainability issues, in the broad sense expressed by the SDGs defined by the United Nations (https://sdgs.un.org/goals), and to stimulate research activities that can impact these goals.
In our research activities, we often address fundamental aspects related to sustainability, such as studying solutions to improve working conditions, reduce energy consumption, and minimize material usage. Therefore, the I4SDG congress encompasses all the themes commonly developed within our scientific community.
You can participate with a full paper, which will be published in the Springer proceedings indexed by Scopus, or with an abstract.
The deadlines are:
- Full paper or abstract submission: December 12, 2026
- Notification of acceptance: January 30, 2027
- Final paper submission: February 27, 2027
- Early registration before: February 22, 2027
It is possible to propose invited tracks dedicated (special sessions) to specific themes. (Contact us if you are interested in proposing a track by November 27th , med.amine.laribi@univ-poitiers.fr. )
More information on Special sessions in available on: IFToMM for Sustainable Development Goals – Sciencesconf.org
More information on I4SDG 2027 is available on the website https://i4sdg.sciencesconf.org/
Please, find attached the call for papers
See you in Tunisia!!!
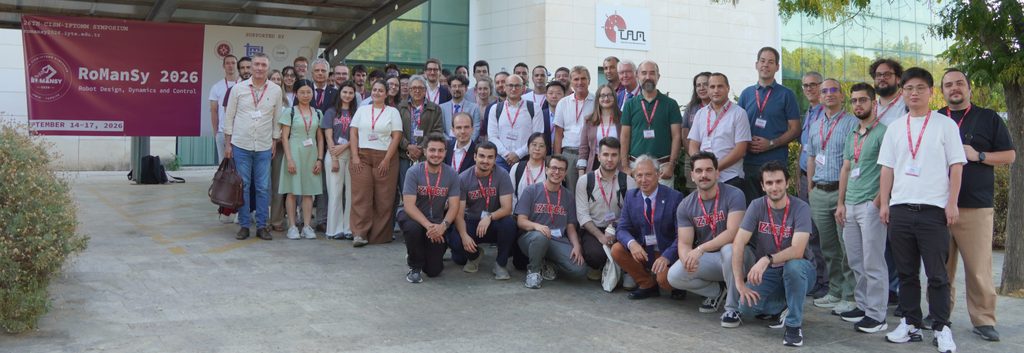
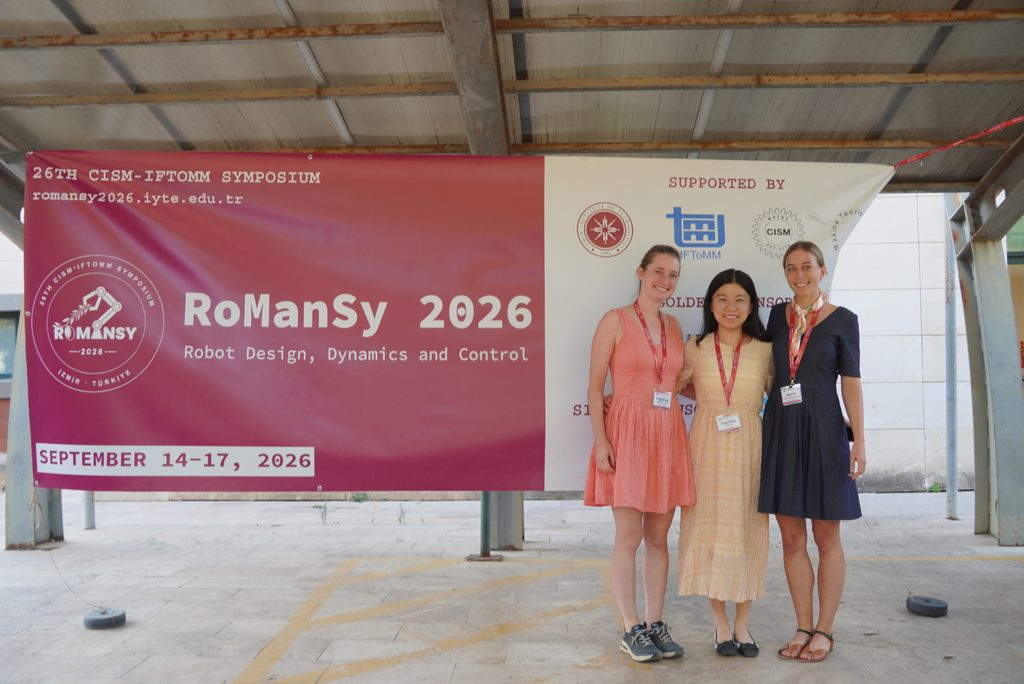
The RoManSy tradition of IFToMM continued with the 26th CISM IFToMM Symposium on Robot Design, Dynamics and Control (RoManSy 2026), hosted by the Izmir Institute of Technology in Izmir, Türkiye. RoManSy 2026 received submissions spanning from Japan to Italy, from Kazakhstan to Germany, and from the USA to France, covering vital areas of robotics research such as robot control, robot mechanism design, soft robotics, medical robotics, and robot manipulators. To foster the exchange of advanced perspectives and encourage collaborative discourse, the symposium program features single-track technical sessions, supplemented by dedicated networking intervals, formal meals, and cultural excursions.
The plenary track features three distinguished keynote speakers from the Netherlands, China, and Türkiye, who presented cutting-edge research carried out in their respective institutions on soft robots, rigid-flexible hybrid mechanisms, and physical human-robot interaction. We extend our sincere appreciation to the keynote speakers for their insightful contributions to the program. Additionally, we thank Siemens Türkiye for organizing a specialized technical session, which introduces the forum to modern paradigms in Smart Robotics.
After a peer-review process, 51 full papers were accepted. Among them, 50 papers were presented and discussed across 13 single-track sessions. The chairs of RoManSy 2026 express their sincere gratitude to the authors for their high-quality contributions, and to the reviewers, members of the international scientific committee, and members of the advisory board for their invaluable time and dedication in ensuring the academic excellence of this historical event.
We thank IFToMM and CISM for providing the patronage to the Symposium, MakTeD for their vital local organization support, and Izmir Institute of Technology (IZTECH) for hosting the symposium. We are also deeply grateful to our sponsor companies Siemens Türkiye, Güralp Winch, BİAS Engineering, and ESKA for their financial support. Finally, we thank all participants for making the 26th RoManSy a highly successful and memorable event by bringing together global researchers and pioneering ideas.
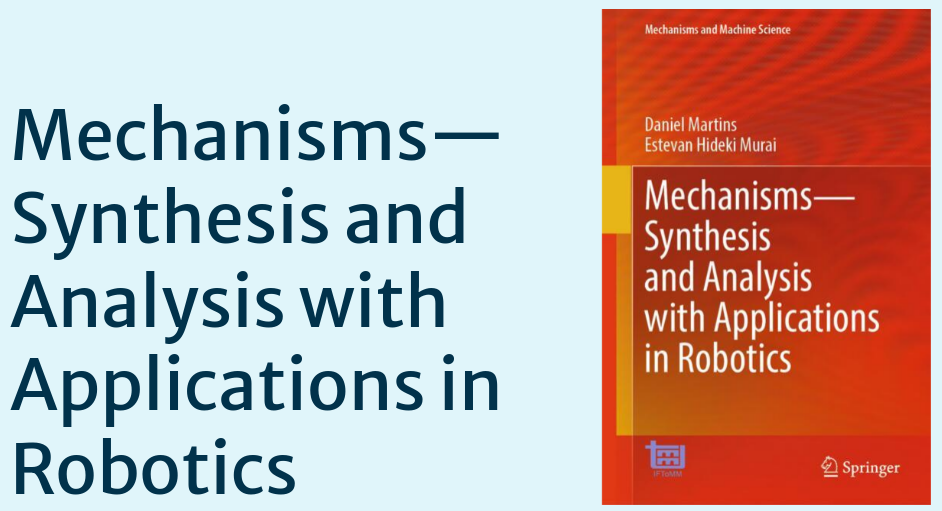
This book serves as an introductory course on mechanisms with robotics concepts for undergraduate students. Concepts are presented aiming to support the mechanical design of robots. Basic concepts from mechanism theory are presented to provide a base for designing mechanisms in general.
Part I of the book examines the introductory concepts of mechanisms theory and serves as a basis for analyzing and designing mechanisms. Part II presents the analysis of four-bar linkages, including the Grashof criterion and the transmission quality; structural analysis of mechanisms, including concepts used in robot design such as connectivity and redundancy; and kinematic analysis of mechanisms, including analysis of position, velocity, and acceleration. Part III describes the number and type syntheses of mechanisms; dimensional synthesis of four-bar linkages for two and three positions; dimensional synthesis for function generation and crank-rocker mechanism.
Examples of mechanism analysis and synthesis are shown using Geogebra or Octave. At the end of each chapter, specific references for each topic are presented as well as a list of exercises with gradually increasing difficulty, designed to help undergraduate students understand the subject.
Book’s URL: https://link.springer.com/book/10.1007/978-3-031-95187-9
About the authors:
Daniel Martins is professor of Mechanical Engineering at the Federal University of Santa Catarina, Brazil. His research interests include mechanism design and robotics, kinematics, statics and dynamics of mechanical systems with emphasis on mechanical design.
Estevan Hideki Murai is professor at the Federal University of Santa Catarina, Brazil. He has lectured mechanism and machine design. Currently, he lectures CAD modeling and product design. His research interests include mechanism design, machine design and robotics with emphasis on mechanical design.
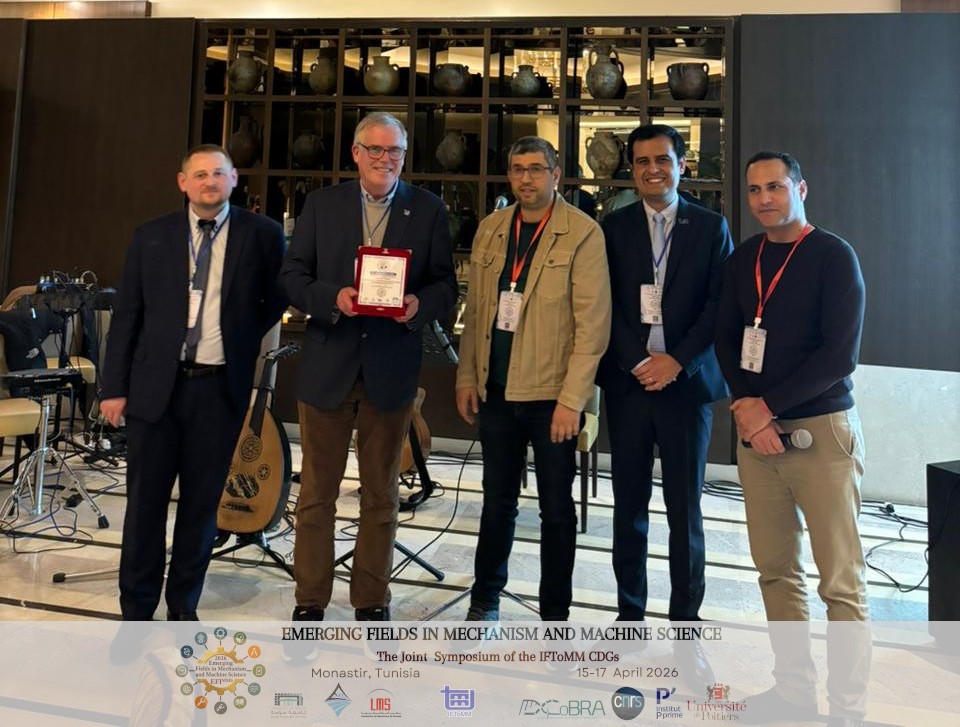
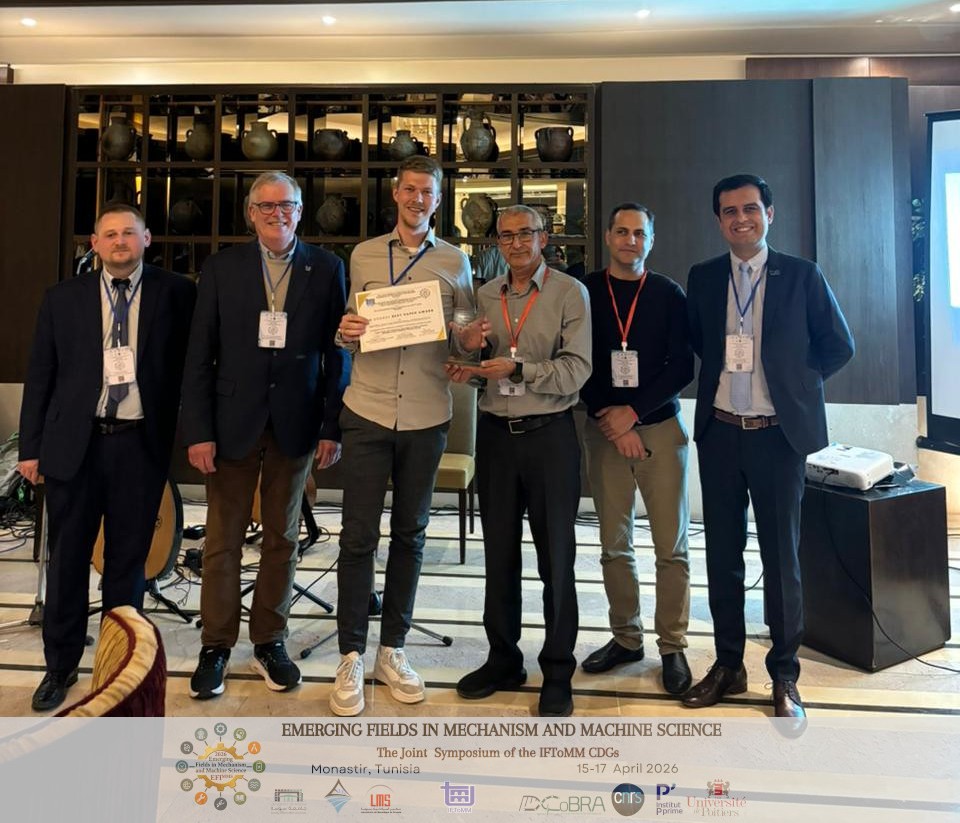
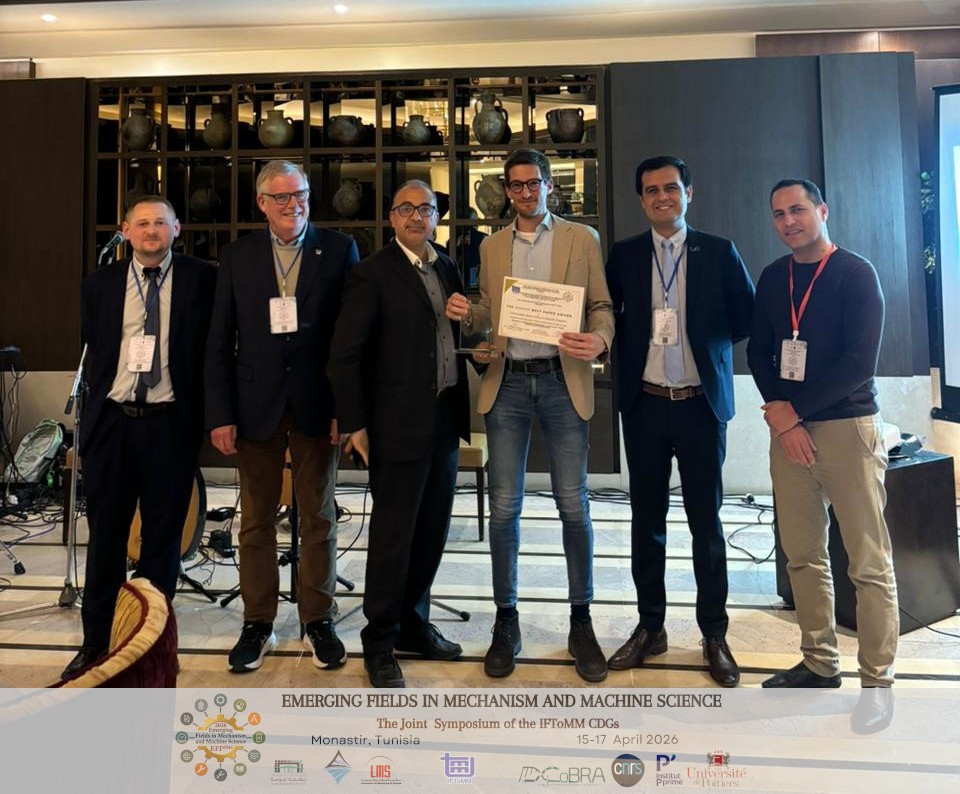
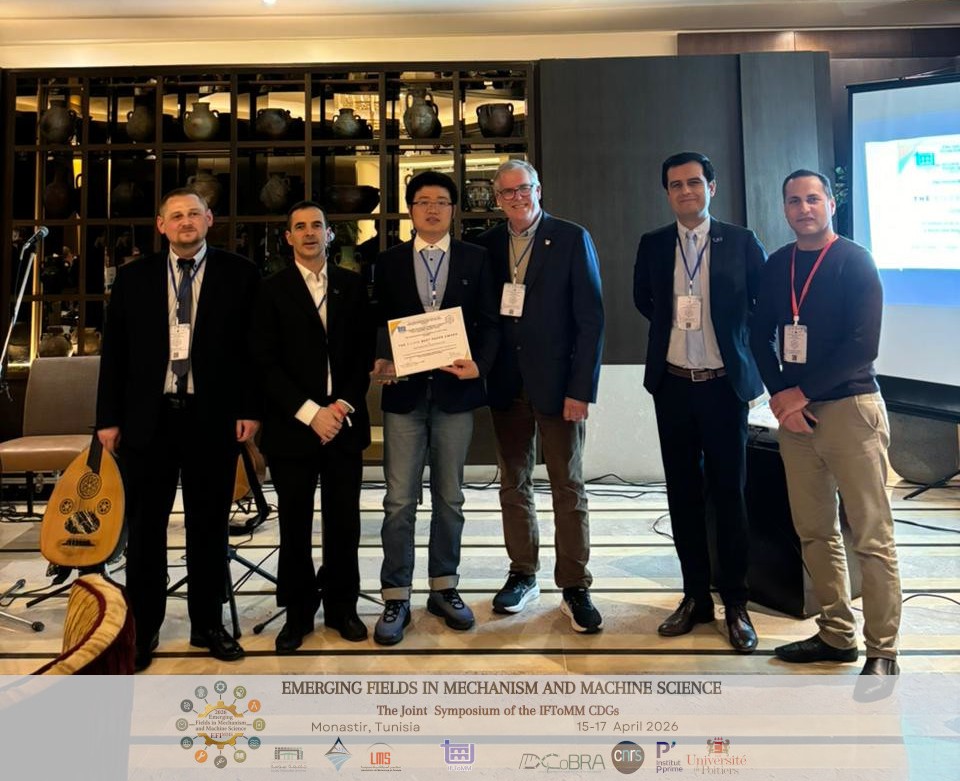
A throwback to the successful 2nd IFToMM International Symposium on Emerging Fields in Mechanism and Machine Science (EFIMMS 2026), the first joint symposium of the IFToMM Cross-Disciplinary Groups: the IFToMM Young Faculty Group, the IFToMM Women’s Group (WG), and the IFToMM Graduate Student Group (GSG). The event was held in Monastir, Tunisia, on April 16–17, 2026. https://iftomm-yfgs2026.sciencesconf.org
Organized jointly by the University of Sousse (Tunisia) and Pprime Intitute at the University of Poitiers (France), it was a highly enriching and convivial scientific gathering, bringing together young researchers from 18 countries and featuring high-quality scientific papers.
Special thanks to our guest speakers, Prof. Andrés Kecskeméthy (University of Duisburg-Essen, IFToMM President) and Prof. Daniele Cafolla (Swansea University), for their valuable and motivating keynote lectures. Our thanks are also extended to Prof. Paulo Flores, Editor-in-Chief of the Mechanism and Machine Theory (MMT) Journal, for his participation and support of the awarded papers.
As part of the conference, two exceptional events were organized:
A highly enriching round table on young researchers’ engagement in science through the IFToMM community, followed by a series of meetings of the IFToMM cross-disciplinary groups.
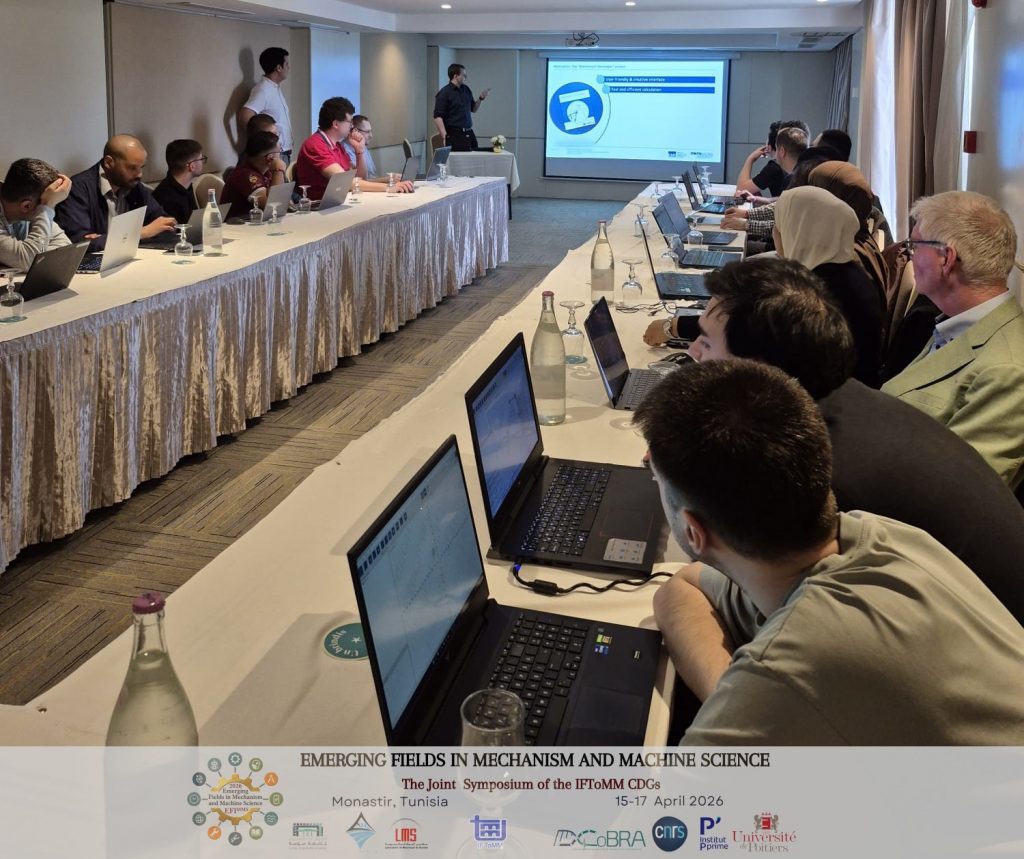
A workshop on the MechDev software for mechanism analysis and simulation, led by Vincent Brünjes from RWTH Aachen University, Germany.
The next EFIMMS is on its way, stay tuned for updates!
The 7th Students International Olympiad on Mechanism and Machine Science (SIOMMS 2026) was held on April 15-18, 2026 in Shandong, China. The Olympiad was organized by Shandong University (Weihai Campus) with the support of IFToMM China-Beijing and IFToMM PC for Education. This international event attracted 14 teams from 4 countries including Russia, Spain, Romania, and China, with a total of 42 students participating in the competition.
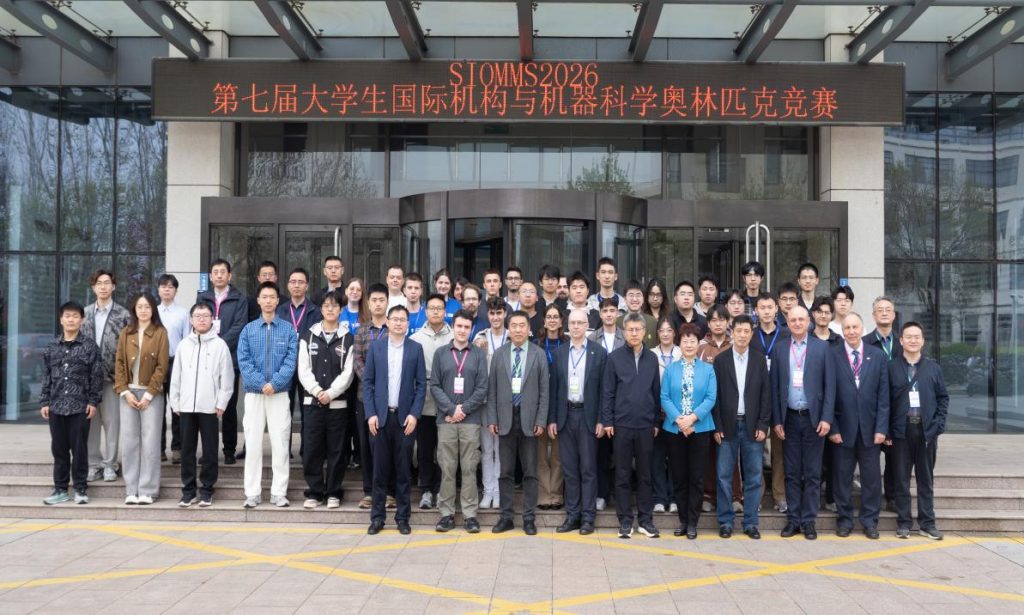
(Group photograph)
Professor Cristina Castejón, the Vice President of IFToMM, delivered a warm welcome speech via video link, extending her best wishes for the success of the event. Professor Eduard Krylov, the Chair of IFToMM PC for Education, and Professor Zhanqiang Liu, the Vice President of Shandong University, also delivered welcome speeches at the opening ceremony.
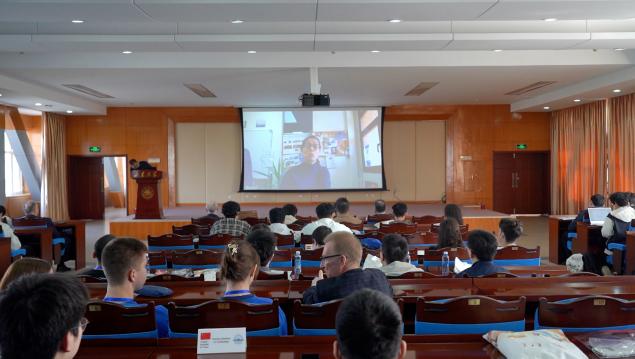
(Professor Cristina Castejón delivering a welcome speech)
(Professor Eduard Krylov delivering a welcome speech)
(Professor Zhanqiang Liu delivering a welcome speech)
The theme of SIOMMS 2026 is “Deepening Mechanical Principles, Empowering Innovative Practice”. The Olympiad focused on the theories of mechanisms and machine science as well as core knowledge of mechanical principles, integrating academic rigor and practical application. It was designed to inspire university students’ enthusiasm for mechanisms and machine science-related fields and helped participants deepen their understanding of professional knowledge, enhance practical application skills, and cultivate comprehensive competence in solving complex mechanical engineering problems through competitions and academic exchanges.
In the competition, contestants were required to answer six theoretical questions in a continuous four-hour period. Prizes were bestowed to acknowledge outstanding individuals and teams. In the team competition, three teams from China won the First Prize, five teams from China, Russia, and Romania were awarded the Second Prize, and six teams from China, Spain, and Russia were awarded the Third Prize. In the individual competition, four students from China won the First Prize, four students from China were awarded the Second Prize, and eight students from China, Spain, and Romania were awarded the Third Prize. Special nominations were also awarded for Perfect Solution for Structural Synthesis, Perfect Solution in Kinematics, Perfect Solution for Gears, and Perfect Solution in Dynamics.
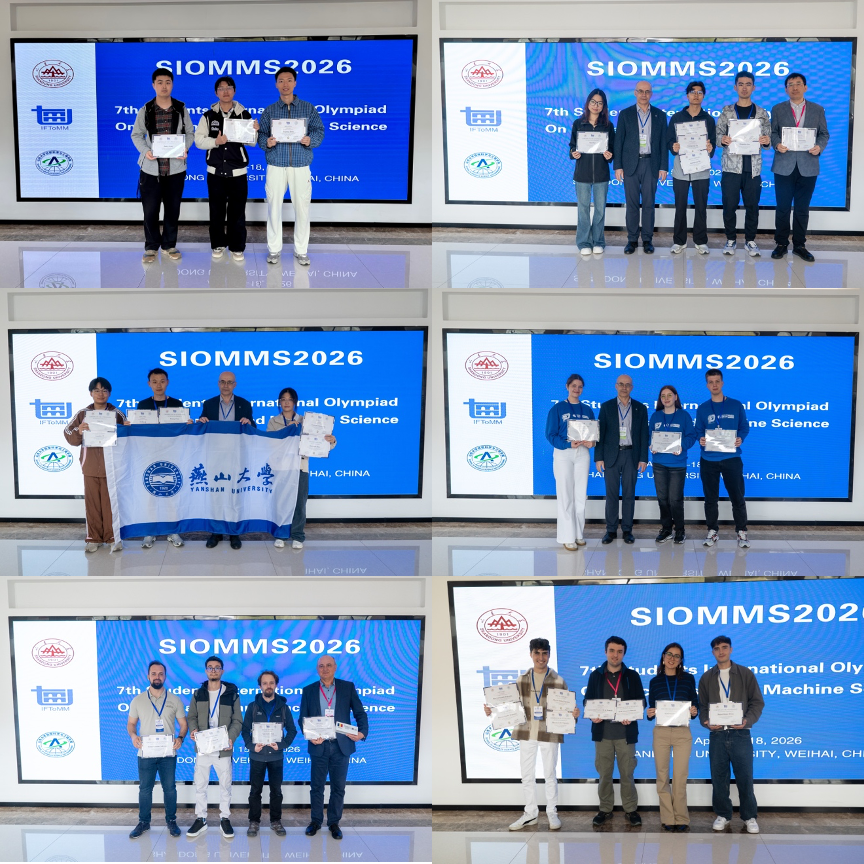
(Several awarded teams)
(Professor Eduard Krylov announcing award recipients at the closing ceremony)
During the event, the International Forum on Advanced Machinery and Mechanisms was held concurrently, promoting in-depth academic exchanges among scholars and participants. Social activities, including lab tours and city tours, were also arranged by the local organizing committee.
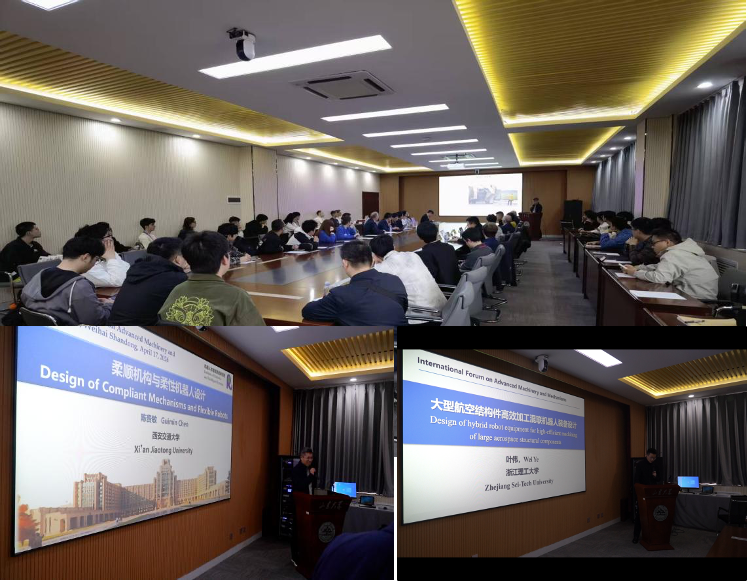
(the International Forum on Advanced Machinery and Mechanisms)
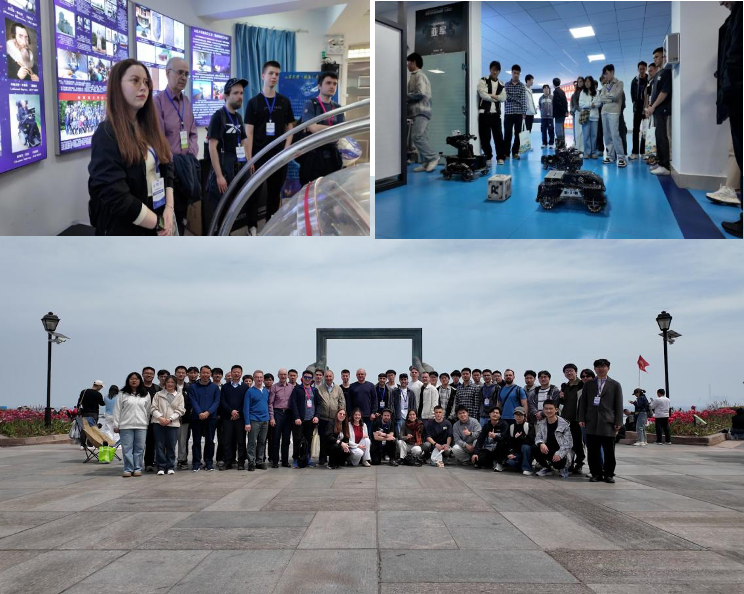
(Lab tours and city tours)
SIOMMS 2026 deployed a dedicated team of volunteers to ensure seamless support for all participating teams. These volunteers are selected from students majored in Russian, Spanish, and other related languages at the School of Translation at Shandong University. The volunteers provided full-time assistance and accompanied each team during their stay in Weihai.
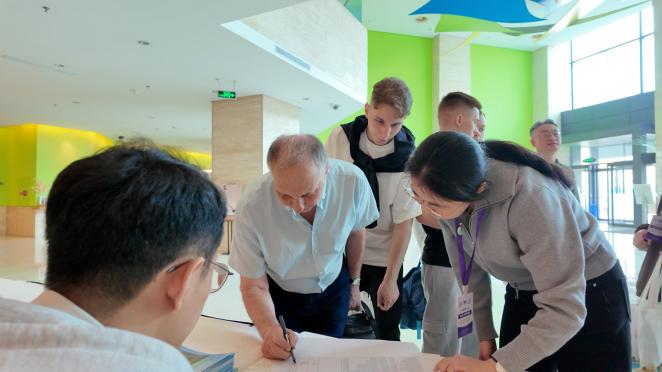
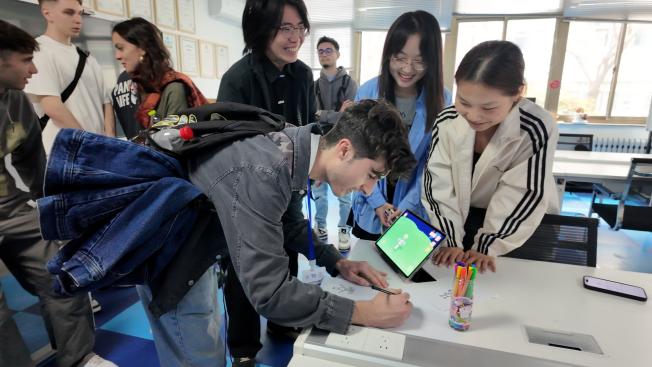
(Volunteers at registration)
SIOMMS 2026 successfully established a platform for international communication among young scholars in mechanical engineering in both professional and cultural contexts. It exhibited the global contribution to the education in Mechanism and Machine Science within the IFToMM community. The vital role of education and communication in the development and prosperity of IFToMM was also highlighted.
Shandong University cordially invites university teams to participate in the 7th Students International Olympiad on Mechanism and Machine Science (SIOMMS), to be held from April 15 to 18, 2026. This edition will continue the tradition of previous Olympiads, which were successfully hosted in 2011 at Izhevsk State Technical University, Russia; in 2013 at Shanghai Jiao Tong University, China; in 2016 at Universidad Carlos III de Madrid, Spain; in 2018 at the Pontifical Catholic University of Peru in Lima, Peru; in 2022 again at Universidad Carlos III de Madrid, Spain; and in 2025 at Satbayev University, Kazakhstan.
Topics
Mechanism Analysis
- Structural analysis and synthesis of mechanisms
- Kinematics of a plane and spatial mechanisms
- Force analysis of mechanisms
- Kinematic analysis of cam mechanisms
Transmission & Dynamics
- Gear transmissions (kinematics, geometry, efficiency)
- Dynamic characteristics adjustment, mechanical regulators
- Balancing of rotating masses
- Manipulators
The 6th Student International Olympiad on Mechanisms and Machine Science (SIOMMS 2025) was held from November 26 to 28, 2025, in Almaty, Republic of Kazakhstan. The Kazakhstan IFToMM National Member Organization, Satbayev Kazakh National Research Technical University, and the Joldasbekov Institute of Mechanics and Engineering organized the Olympiad, with the support of the Ministry of Science and Higher Education of the Republic of Kazakhstan.
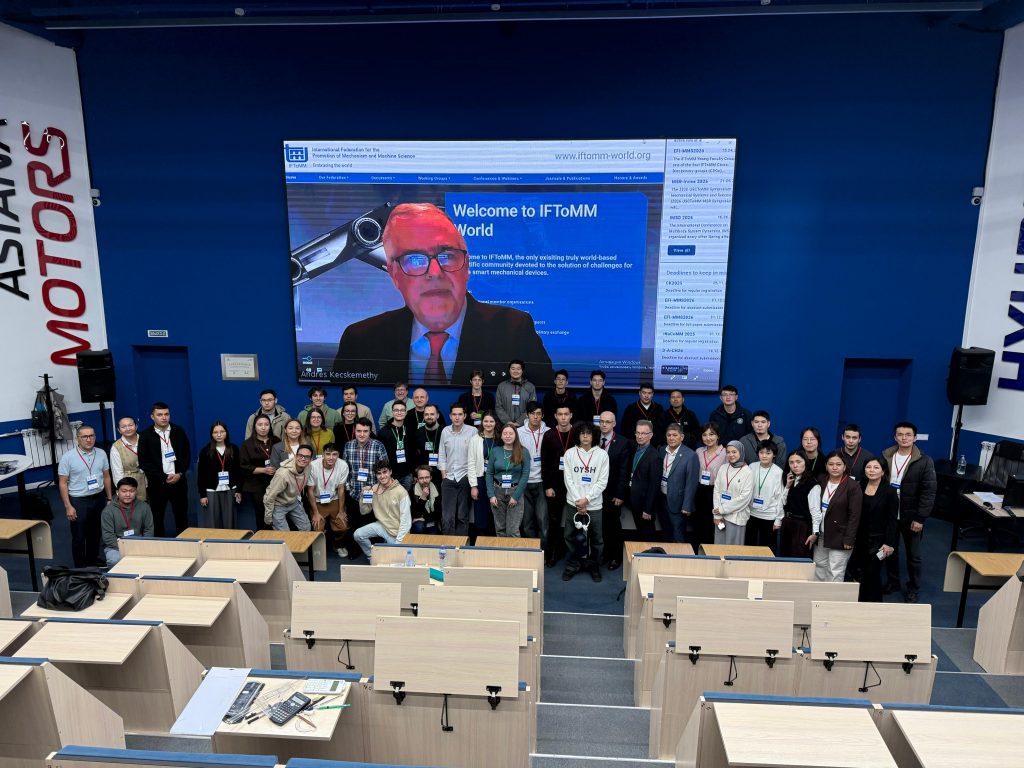
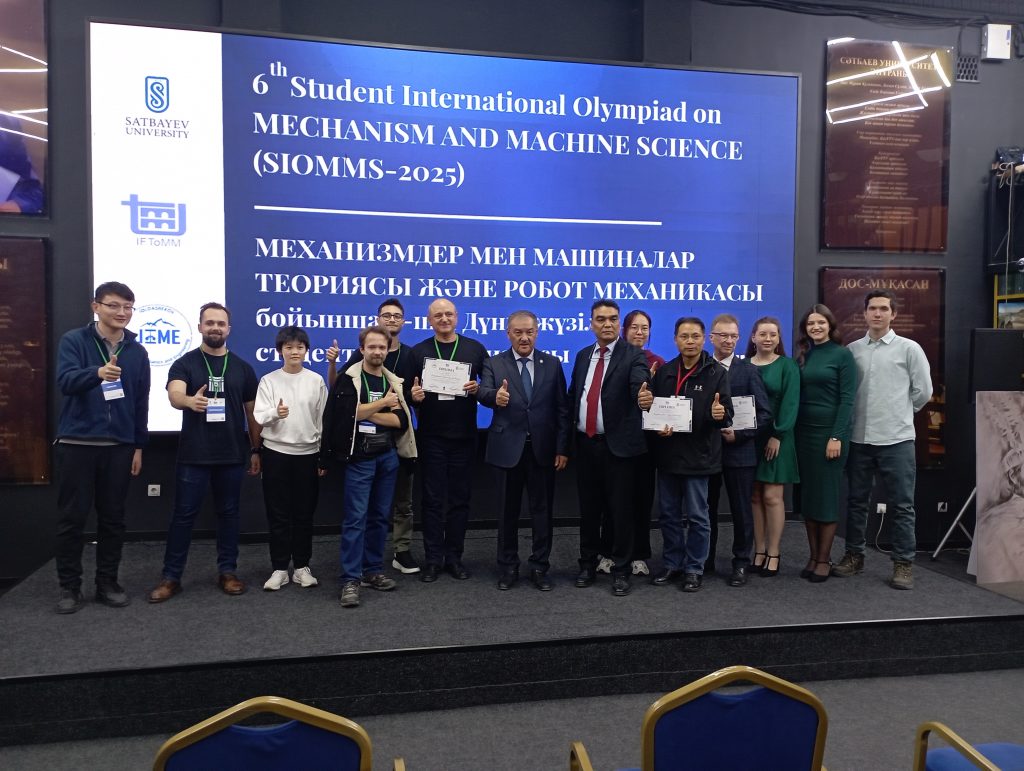
The international event brought together 11 student teams from 6 countries, including Kazakhstan, China, Spain, Romania, Russia, and Kyrgyzstan, with a total of 33 participants representing leading technical universities and research institutions. The Olympiad focused on fundamental sections of Mechanisms and Machine Science (MMS) and aimed to promote analytical thinking, engineering culture, and international academic cooperation among young researchers.
The competition program consisted of eight theoretical problems covering the main areas of MMS. Participants were given four hours to solve the tasks, demonstrating a high level of theoretical knowledge, analytical skills, and engineering reasoning. The evaluation was conducted by an international jury chaired by Professor Sayat Ibrayev.
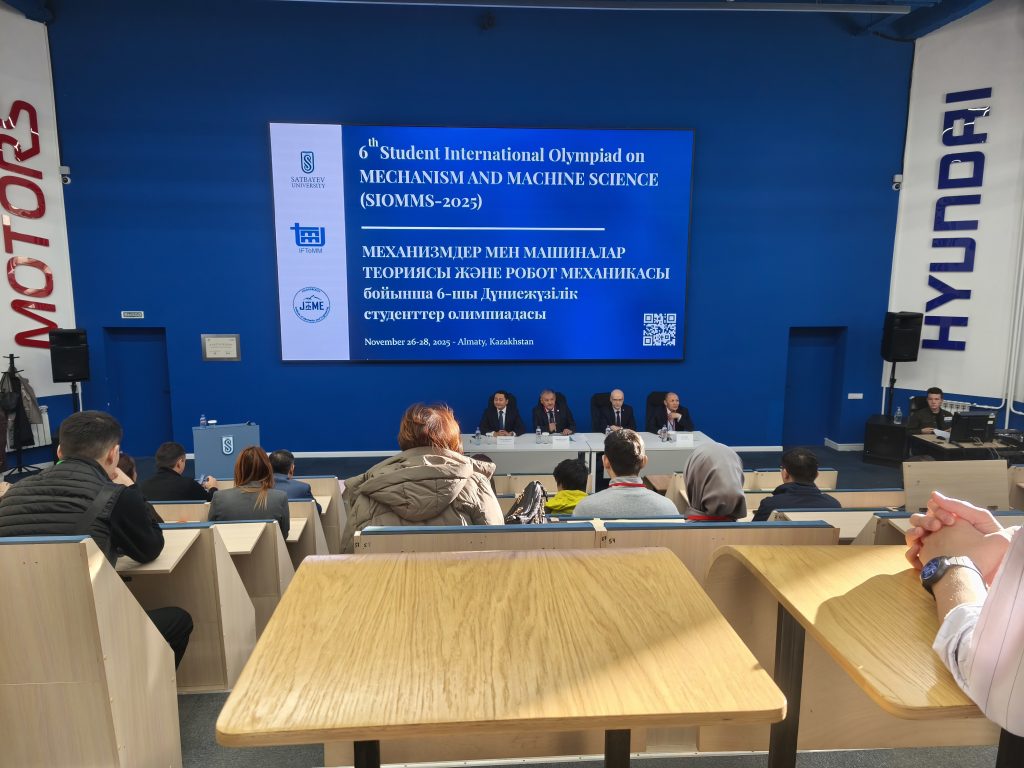
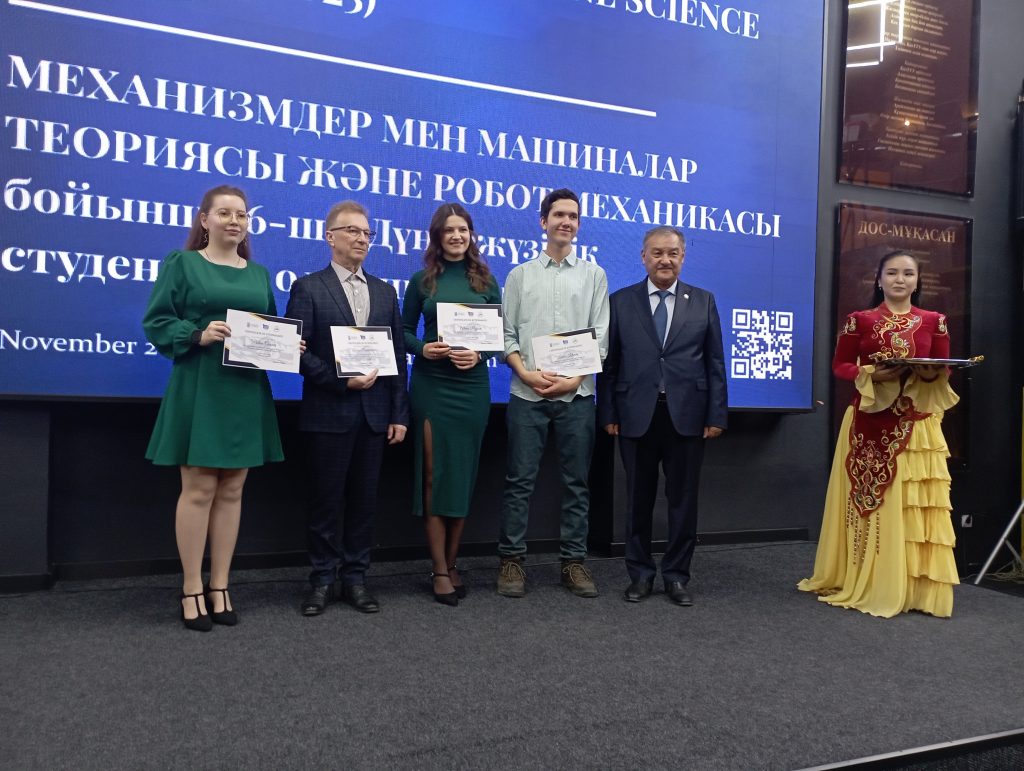
A distinctive feature of SIOMMS 2025 was the introduction of monetary prizes for outstanding individual performance. For the first time in the history of the SIOMMS Olympiad worldwide, the Kazakhstan IFToMM National Member Organization established cash awards for top-performing students, making the Kazakhstan MMS community the first to introduce financial incentives within the SIOMMS framework. The prizes were awarded to eight participants who achieved the highest individual scores.
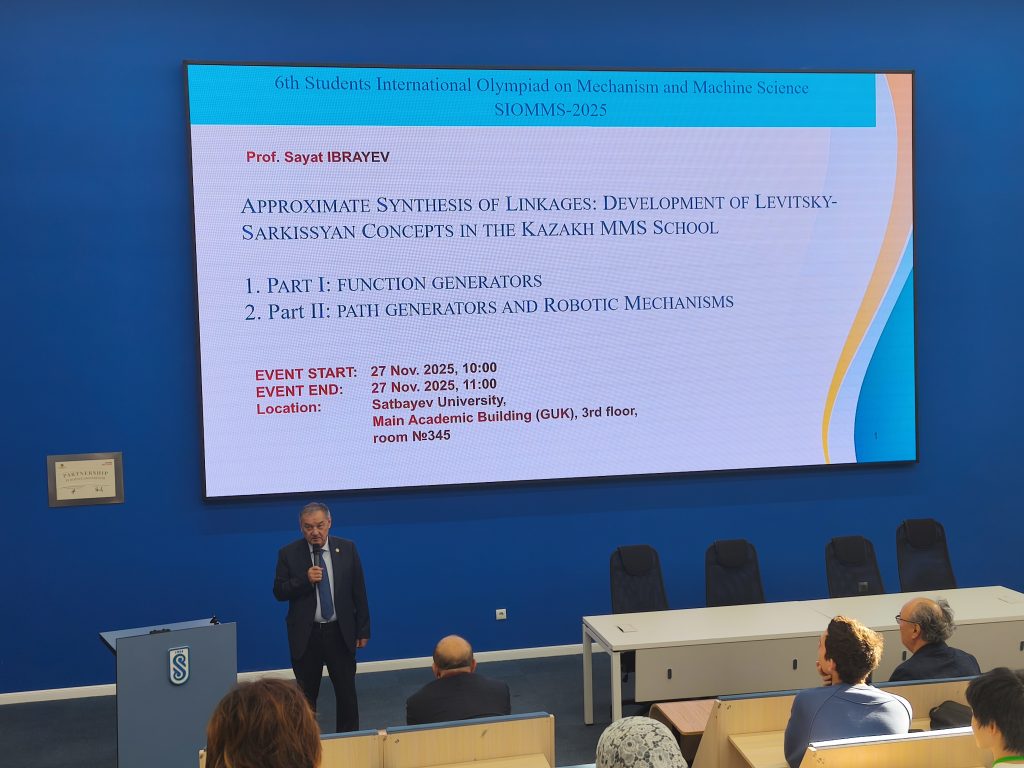
In addition to the competition, the Olympiad included a scientific and educational program, featuring a lecture by Professor Sayat Ibrayev entitled “Approximate Synthesis of Linkages: Development of Levitsky–Sarkissyan Concepts in the Kazakh MMS School”, as well as an open meeting of the IFToMM Permanent Commission on Education. Participants also attended laboratory tours and cultural events.
The Olympiad concluded with an awards ceremony recognizing team and individual achievements, notable nominations, and the contribution of organizers and mentors. SIOMMS 2025 highlighted Kazakhstan’s leadership role in advancing MMS education and its proactive contribution to the global SIOMMS tradition.
YouTube Channel:
Despite numerous outstanding publications on mechanism mobility, many nuances of this topic remain challenging for students and are often discussed only among specialist researchers. These animated lectures, supported by the textbook Mobility of Mechanisms and Robot Manipulators, aim to clarify and make more accessible the concepts related to degrees of freedom in mechanical systems and the methods used to determine them.
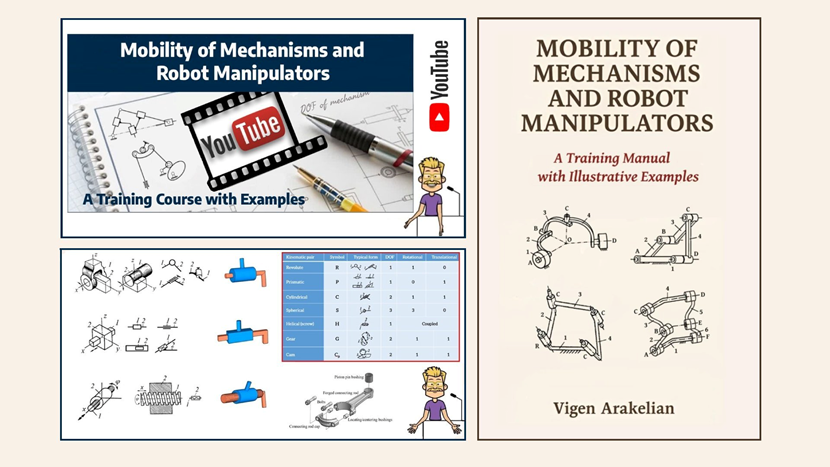
The series presents techniques for calculating mobility across several categories: Regular mechanisms (isostatic systems, both spatial and planar, including open and closed kinematic chains); Hybrid mechanisms; Robot manipulators; Mechanisms with idle (passive) degrees of freedom; Overconstrained mechanisms.
Special attention is given to overconstrained mechanisms, analyzed through a table representing the rank of the velocity matrix of a kinematic chain as a function of the arrangement of kinematic pairs.
The final lecture examines Assur groups with zero mobility, structural synthesis of mechanisms based on the Chebyshev–Grübler–Kutzbach mobility criterion, and the effects of singular configurations on mechanical system mobility.
To reinforce understanding, practical examples are emphasized throughout. The third lecture encourages students to apply their knowledge by solving over 100 exercises from the textbook, each accompanied by a detailed solution and commentary.
It is hoped that these lectures will serve as a valuable resource not only for mechanical engineering students, but also for doctoral candidates and early-career faculty members seeking a deeper grasp of mechanism mobility.
Contact: mechanisms.rennes@gmail.com
The 9th IFToMM International Workshop On New Trends In Medical And Service Robotics took place on July 2-4, 2025, in Futuroscope-Poitiers, France.
Chaired by Prof. Med Amine Laribi, Prof. Giuseppe Carbone, Prof. Doina Pisla and Prof. Said Zeghloul, the event attracted about 85 scientists, engineers, doctors, students and guests from 15 countries China, Colombia, EAU, France, Germany, Italy, Japan, Kazakhstan, Mexico, Romania, Spain, Taïwan, Tunisia, Turkey, UK, USA.
The event was excellently hosted: the conference and the exhibition – by the Fundamental and Applied Science Faculty at the University of Poitiers, and the professional exhibition, as well as the round-table discussion.
We thank Université de Poitiers of Poitiers, in particular, the Fundamental and Applied Science Faculty, for having hosted the MeSRob’25 event.
Thanks to the support of IFToMM. Sponsors: STÄUBLI and MathWorks
The proceedings contain 55 papers and can be accessed through the conference website at https://iftomm-mesrob2025.sciencesconf.org/
or directly at the Springer website https://link.springer.com/book/10.1007/978-3-031-96081-9
 Find your